Embedded systems
Sensor integration, state machines, filtering, communication protocols, and device-side C/C++.
Open to engineering internships
Computer Engineering @ University of Michigan
01 / About
My work has taken me from wiring robot control systems and synthesizing FPGA designs to building sensor-driven ESP32 firmware and tracing enterprise workflow data.
Across those settings, the method is consistent: understand the interface, make system state observable, test assumptions, and document a solution others can trust.
Sensor integration, state machines, filtering, communication protocols, and device-side C/C++.
FPGA design, lab instrumentation, circuit prototyping, electrical integration, and fault isolation.
SQL-backed workflows, Python data collection, HTTP/JSON interfaces, and clear operational logic.
Controlled experiments, regression tests, measurement interpretation, and production-minded verification.
02 / Selected projects
Three projects that show how I approach hardware-software systems at different layers.
Connected Embedded Prototype
A verified ESP32 prototype that turns time-of-flight distance state into package arrival and removal events, then exposes the event path locally and over MQTT.
Distance readings enter the system over I²C before filtering and state evaluation.
A focused next step for the prototype—not a completed result.
Add event-triggered camera capture and lightweight on-device classification, then combine visual and distance evidence to reduce false triggers. The final system will be evaluated with classification accuracy, inference latency, and a 24–72 hour reliability test.
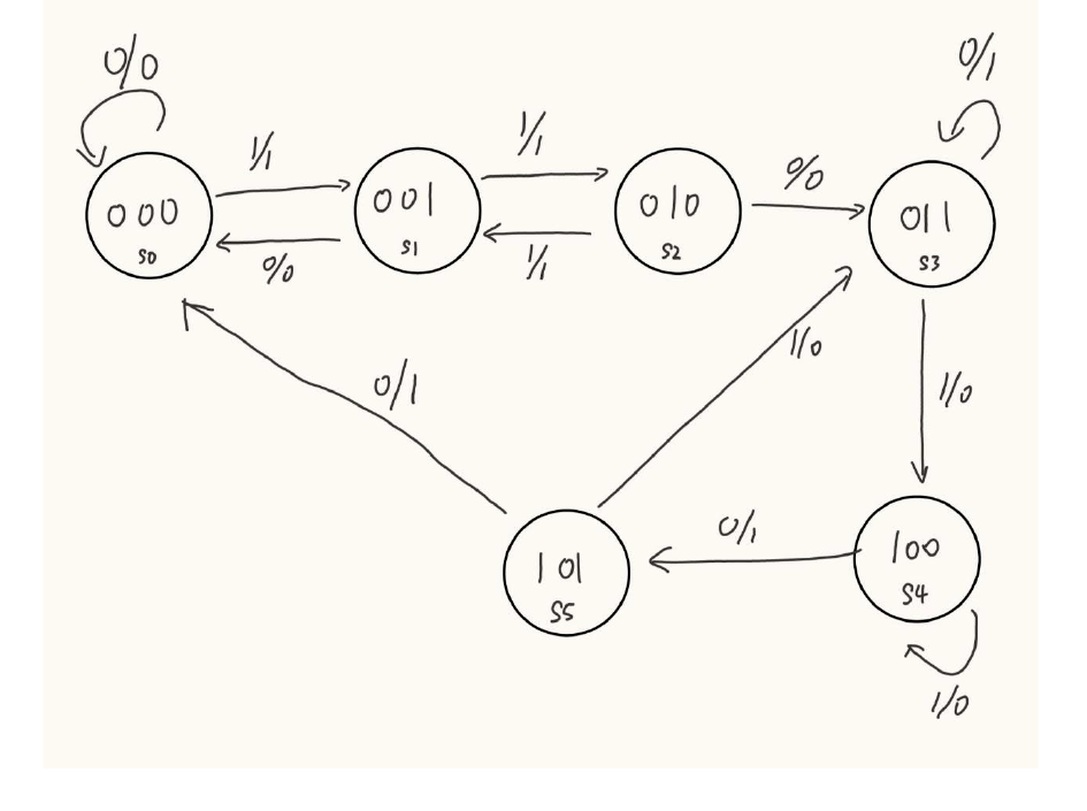
A ten-lab digital design sequence that built toward one meaningful capstone: a Mealy FSM-based bitstream encryption device implemented on a DE0-CV FPGA.
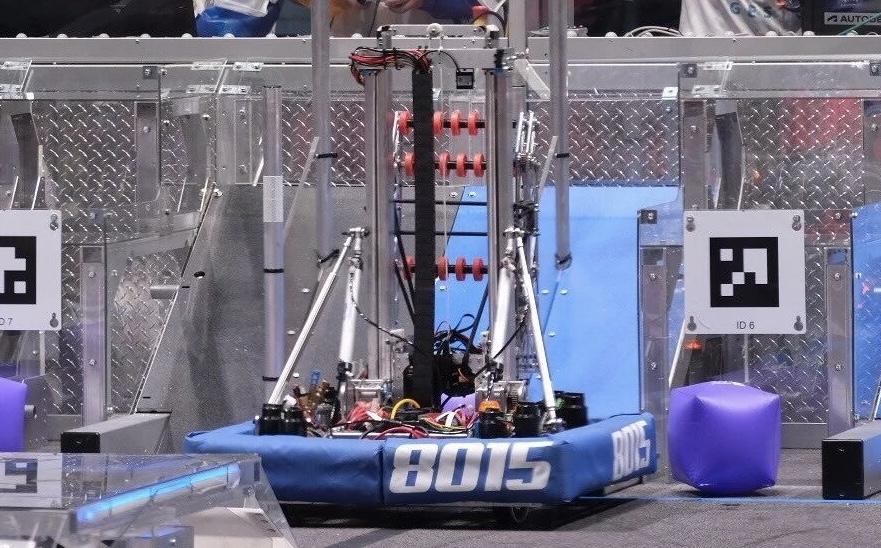
Supported the electrical and vision stack of a competition robot, from controller wiring to subsystem testing and fault isolation.
Coursework / ECE 112 Logic Design
The earlier labs were the foundation, not the portfolio headline: logic gates, Verilog, adders, multiplexers, display drivers, timing and hazards, and counters. The capstone pulled those ideas together into a sequential system that recognizes bit patterns and changes its output mode in real time.
Engineering loop
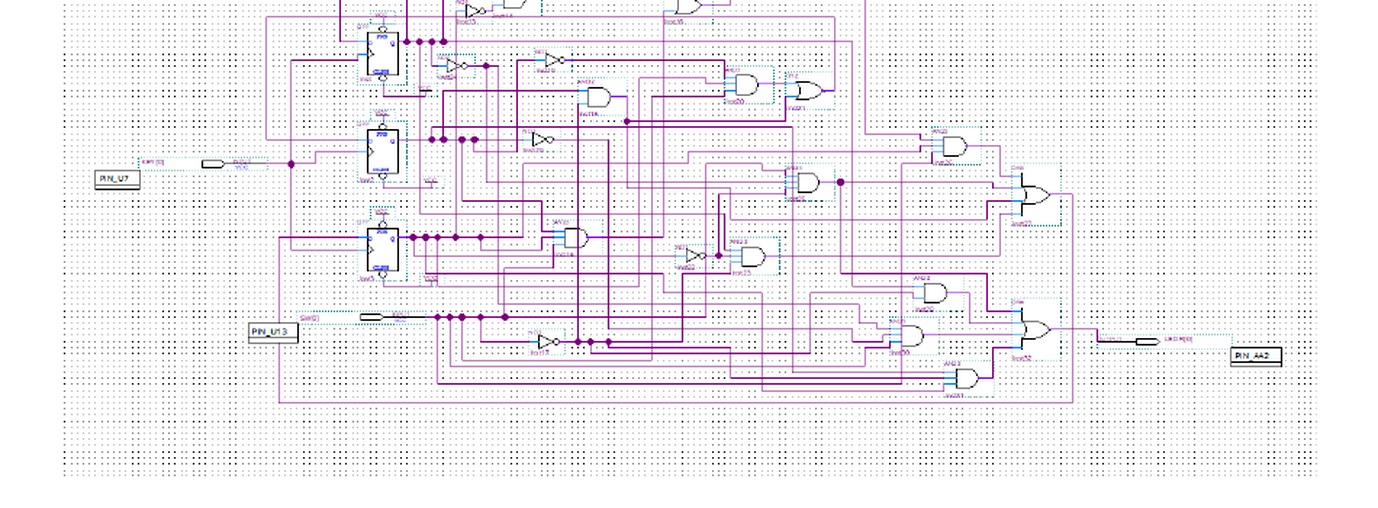
Starting from the two control sequences, I built the state graph and transition table, derived the flip-flop input equations with Karnaugh maps, translated the logic into Quartus, and tested the behavior both in simulation and on the board.
Report result
The report feeds the ASCII message “MAY 10 8:30” through the FSM and records the transformed byte stream:
Figures reproduced from my ECE 112 Lab Report 10. The state graph is my design artifact; the Quartus image is my implementation record. The other labs remain visible as coursework context rather than standalone portfolio projects.
Team 8015 / Robot Electrical Integration
From 2022 to 2024, I supported Team 8015’s robot electrical system, focused on reliable control-system integration, fault isolation, vision hardware, and mentoring.
My responsibility
03 / Experience
Experience spanning industrial automation, technical communication, laboratory equipment, and user-facing troubleshooting.
Eaton Corporation · Shanghai, China
Extended a low-code platform with custom code and SQL, automated supplier and procurement data collection with Python, and created internal technical training resources.
Developed and tested multistage business workflows for four factories, tracing approval logic and data flow to diagnose issues before production release.
University of Rochester · Rochester, NY
Supported experiments with oscilloscopes, multimeters, function generators, power supplies, and circuit components while helping students interpret measurements and experimental error.
04 / Toolkit & education
C++ · C · Python · Verilog
ESP32 · I²C · UART · FPGA · RTL · FSM
Oscilloscope · DMM · Function Generator · Soldering · Circuit Prototyping
Git · CMake / CTest · Quartus II
B.S.E. in Computer Engineering
Ann Arbor, MichiganCoursework in Electrical & Computer Engineering
Transferred to University of Michigan · Dean’s List · Rochester, New YorkLogic Design · Digital Integrated Circuits · Embedded Control Systems · Computer Organization · Semiconductor Devices · Signals and Systems · Programming and Data Structures
05 / Contact
The best way to reach me is by email.
jonathanliyou0623@gmail.com